Aceinna · Inertial systems
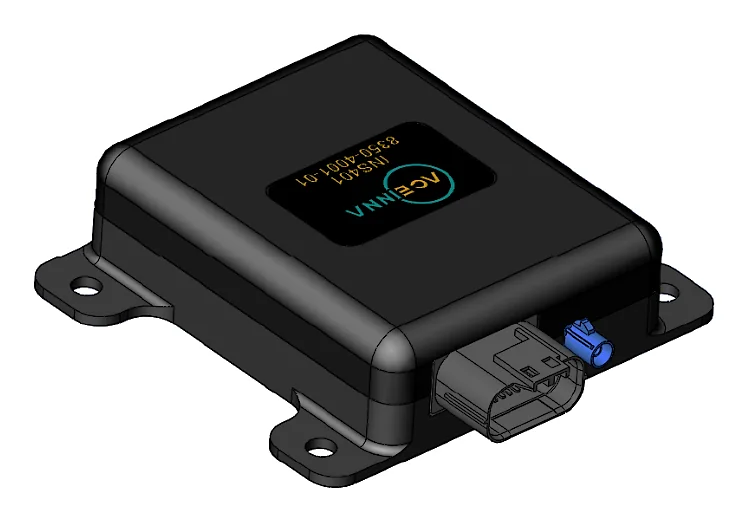
INS401
Automotive GNSS/INS with an RTK receiver and triple-redundant IMU for cm-level positioning.
- RTK 2 cm (RMS)
- Multi-band GNSS
- 100 Hz INS output
- Ethernet, 1PPS
Overview
The INS401 is an inertial navigation system that combines an RTK-enabled multi-band GNSS receiver, triple-redundant MEMS inertial sensors and a positioning engine. It outputs position, velocity and attitude at 100 Hz, with dead reckoning to bridge short GNSS outages in urban environments, and it is qualified for automotive applications. Aceinna designed it for L2+ and higher ADAS and other high-volume applications that need precise position.
Built for
- Autonomous passenger vehicles, robo-taxis and trucks
- ADAS systems
- Agriculture vehicle auto-steer systems
- Construction vehicles
Key features
Multi-constellation GNSS
Tracks GPS, GLONASS, BeiDou, Galileo and QZSS with 80 channels.
RTK corrections
Uses RTCM 3.x corrections from Aceinna OpenARC or third party NTRIP services.
Dead reckoning
The IMU fills gaps between GNSS updates and during short outages.
Triple-redundant IMU
Integrated, calibrated MEMS IMU with +/-8 g and +/-200 deg/s ranges.
OTA updates
Firmware can be upgraded over Ethernet.
Faster start-up
Saves navigation data before shutdown for faster initialization.
Specifications
- Horizontal accuracy, RTK
- 0.02 m RMS (+1 ppm baseline)
- Horizontal accuracy, SPS
- 1.2 m CEP
- Vertical accuracy, RTK
- 0.03 m RMS
- Horizontal, 10 s GNSS outage
- 0.35 m
- Velocity accuracy
- 0.02 m/s RMS
- Heading accuracy
- 0.2 deg RMS
- Roll / pitch accuracy
- 0.1 deg RMS
- RTK initialization time
- < 10 s
- GNSS update rate
- 10 Hz
- INS output data rate
- 100 Hz
- GNSS chipset
- ST Teseo APP
- Interface
- Ethernet, 1PPS output
- Input voltage
- 9 to 32 VDC
- Power consumption
- < 5 W
- Operating temperature
- -40 to 85 C
- Size / weight
- 115 x 126 x 35 mm, < 500 g
Supported GNSS signals
| Constellation | Signals |
|---|---|
| GPS | L1 C/A + L2C |
| GLONASS | G1 |
| BeiDou | B1I + B2I |
| Galileo | E1 + E5b |
| QZSS | L1 C/A + L2C |
Models and options
- INS401 (Ethernet I/O)
- INS401-C (Ethernet + CAN, contact factory)
- INS402 (dual antenna, contact factory)
- INS401 EVK (contact factory)
Specifications as published by Aceinna. Configurations vary by model; we will confirm the exact build with your quote.
More in inertial systems
All Aceinna products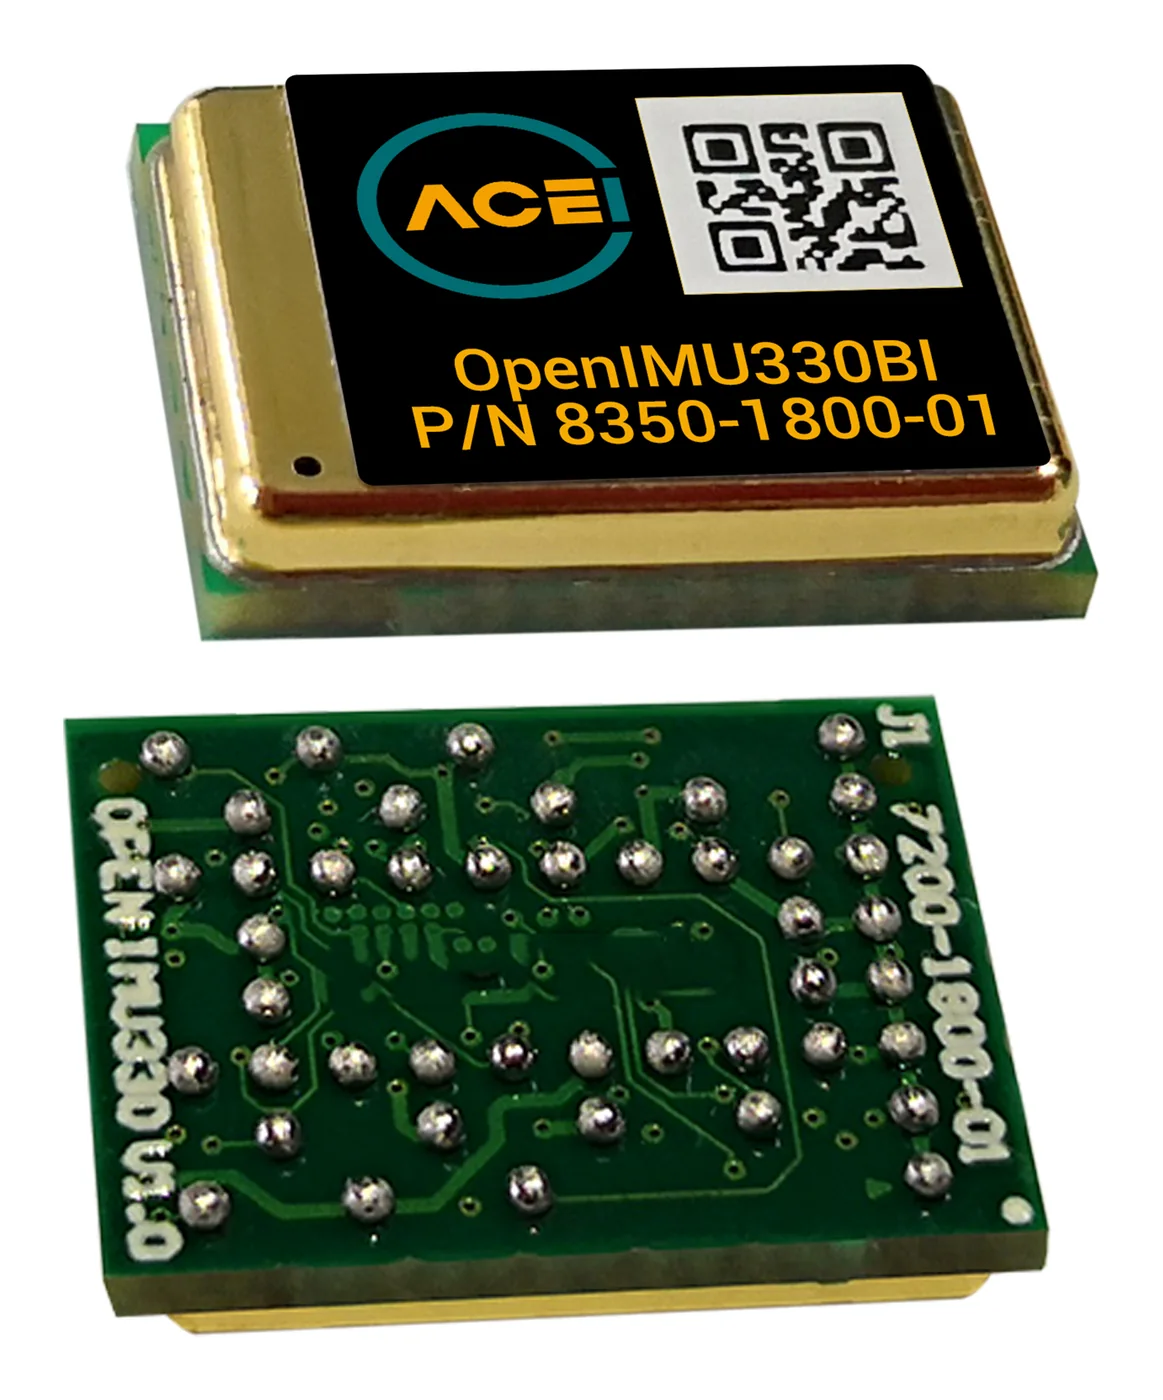
OpenIMU330B
Triple-redundant 6-DOF surface mount IMU that runs the OpenIMU open source navigation stack.
- Triple-redundant 6-DOF
- 1.5 deg/hr gyro bias
- SPI / UART
- 11 x 15 x 3.4 mm BGA
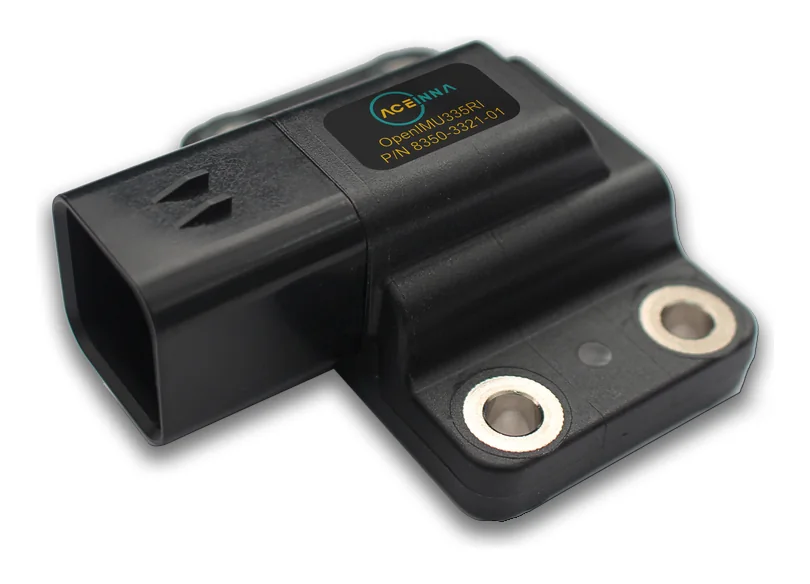
OpenIMU335RI
Rugged, sealed triple-redundant open source IMU with CAN and RS232 for off-road and vehicle use.
- 6-DOF (9-DOF option)
- 1.3 deg/hr gyro bias
- CAN J1939 / RS232
- IP67 / IP69K
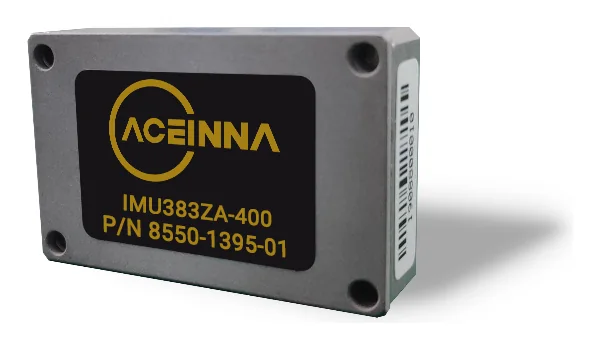
IMU383ZA
Embedded 6-DOF IMU with triple-redundant sensors, a drop-in upgrade for the IMU380ZA and IMU381ZA.
- 6-DOF embedded IMU
- 1.3 deg/hr gyro bias
- SPI or UART
- < 250 mW
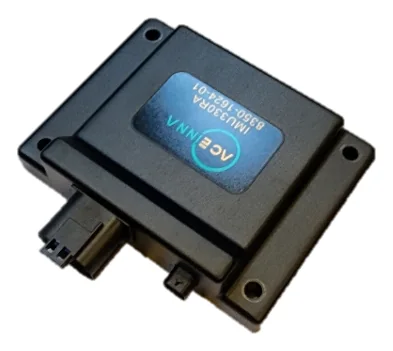
IMU330RA
ASIL B automotive 6-DOF IMU in an IP69K housing with 1000Base-T1 Ethernet and CAN-FD.
- ASIL B, AEC-Q104
- 1000Base-T1 / CAN-FD
- 1 deg/hr gyro bias
- IP69K sealed
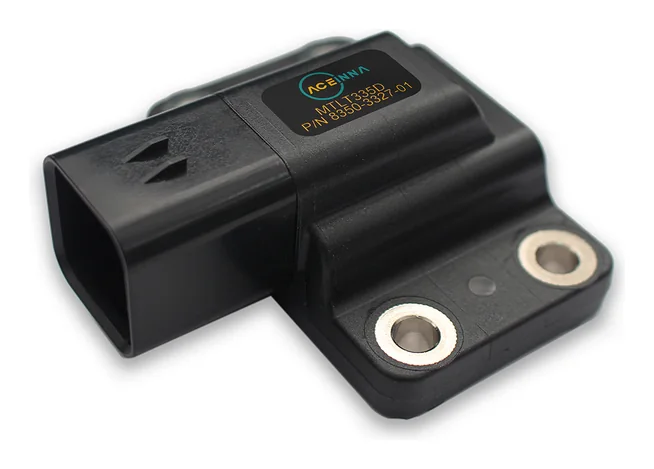
MTLT335D
Triple-redundant dynamic tilt sensor and 6-DOF IMU with CAN J1939, developed to ISO 13849 up to PL d.
- Triple-redundant 6-DOF
- ISO 13849 PL d
- CAN J1939 / RS232
- IP69K, 9 to 32 V
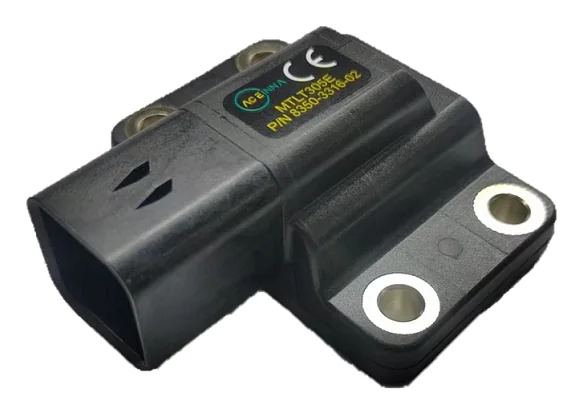
MTLT305E
Lower cost 6-DOF IMU and dynamic tilt sensor with CAN J1939, software compatible with the MTLT335D.
- 0.15 deg static tilt
- 4 deg/hr gyro bias
- CAN J1939 / RS232
- IP69K, 9 to 32 V
Need help choosing?
Tell us your application. We will recommend the right Aceinna product, quote it and support it after delivery.