Aceinna · Inertial systems
OpenIMU335RI
Rugged, sealed triple-redundant open source IMU with CAN and RS232 for off-road and vehicle use.
- 6-DOF (9-DOF option)
- 1.3 deg/hr gyro bias
- CAN J1939 / RS232
- IP67 / IP69K
Overview
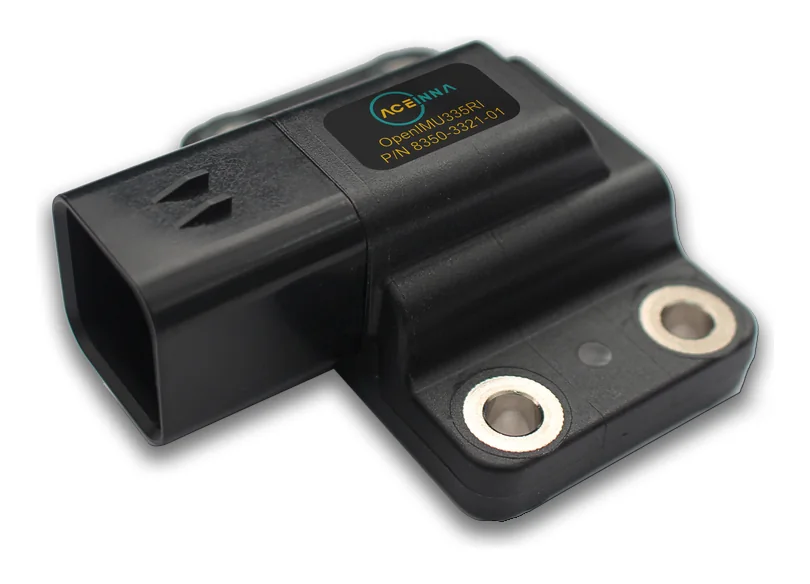
The OpenIMU335RI is a 6-DOF open inertial platform in a rugged, sealed over-molded plastic housing, with a 3-axis magnetometer available as an option. It contains triple-redundant 3-axis MEMS accelerometers and rate gyros calibrated over the operating temperature range, a 168 MHz ARM M4 CPU, and runs the OpenIMU open source stack with a 16-state Kalman filter. It is designed for 12 V and 24 V vehicle platforms in the automotive, construction and agriculture markets.
Built for
- Construction vehicle boom, bucket and cab attitude
- Agriculture vehicles and implements
- Forklifts and robotics control
- Antenna and camera stabilization
Key features
Triple-redundant sensing
Redundant accelerometers and gyros with fault detection.
Open source algorithms
OpenIMU stack with VG, AHRS and INS algorithms and a 16-state EKF.
Wheel speed aiding
Can use wheel speed CAN messages on the bus to improve accuracy.
Flexible mounting
Axes can be reassigned and a user rotation matrix corrects mounting errors.
Vehicle power ready
Runs from 9 to 32 V and is tested to SAE J1455 and ISO 16750-2 electrical loads.
Sealed connector
IP67 Ampseal 16, 6-position connector.
Specifications
- Degrees of freedom
- 6 (9 with optional magnetometer)
- Gyro range
- +/-400 deg/s
- Gyro bias instability
- 1.3 deg/hr
- Angle random walk
- 0.15 deg/√hr
- Gyro bias over temperature
- 0.1 deg/s
- Accel range
- +/-8 g
- Accel bias instability
- 20 µg
- Pitch / roll accuracy
- 0.1 deg over temperature and angle
- Magnetometer range (option)
- +/-8 Gauss
- Interfaces
- CAN 2.0 J1939, RS232
- Max output data rate
- 100 / 200 Hz (CAN / serial)
- Input voltage
- 9 to 32 V
- Power
- 500 mW typ (40 mA at 12 V)
- Operating temperature
- -40 to 85 C
- Size
- 65 x 66 x 27 mm
- Weight
- < 75 g
Models and options
- OpenIMU335RI (industrial grade, 6 DOF)
- OpenIMU335RI EVK (developer kit with JTAG, ST-Link and cable)
Specifications as published by Aceinna. Configurations vary by model, so we will confirm the exact build with your quote.
Buying the OpenIMU335RI in India
Authorised Aceinna distributor
Genuine Aceinna products, sourced directly from Aceinna.
GST invoice
Invoiced in India with GST, so registered businesses can claim input tax credit.
From stock or to order
Some products ship from our stock in India, and we order the rest from Aceinna for you.
Help choosing
Tell us the application and we will recommend the right Aceinna product.
More in inertial systems
All Aceinna products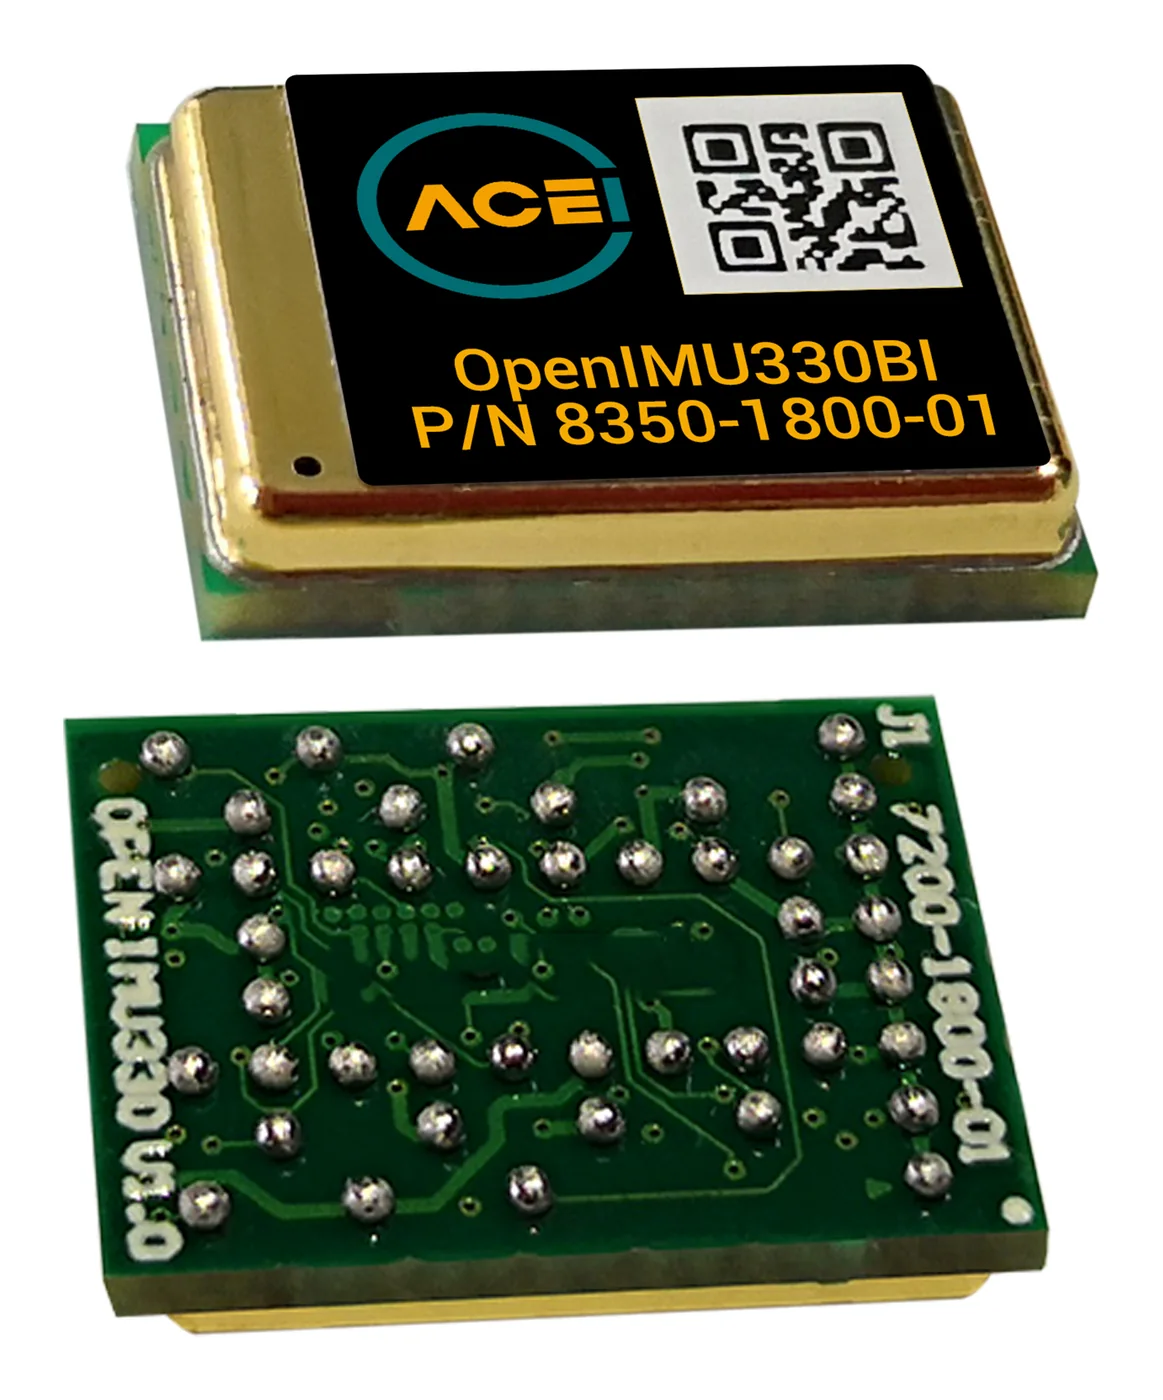
OpenIMU330B
Triple-redundant 6-DOF surface mount IMU that runs the OpenIMU open source navigation stack.
- Triple-redundant 6-DOF
- 1.5 deg/hr gyro bias
- SPI / UART
- 11 x 15 x 3.4 mm BGA
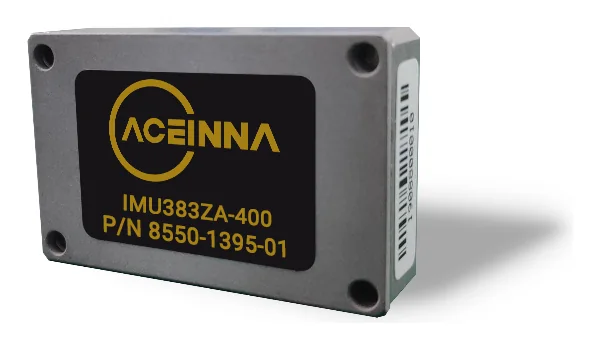
IMU383ZA
Embedded 6-DOF IMU with triple-redundant sensors, a drop-in upgrade for the IMU380ZA and IMU381ZA.
- 6-DOF embedded IMU
- 1.3 deg/hr gyro bias
- SPI or UART
- < 250 mW
IMU330RA
ASIL B automotive 6-DOF IMU in an IP69K housing with 1000Base-T1 Ethernet and CAN-FD.
- ASIL B, AEC-Q104
- 1000Base-T1 / CAN-FD
- 1 deg/hr gyro bias
- IP69K sealed
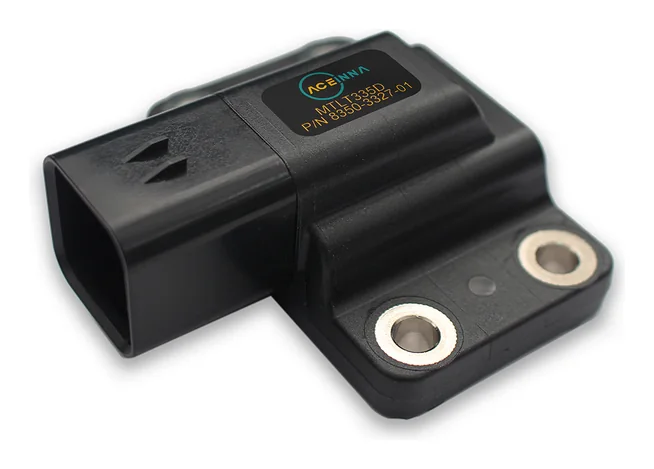
MTLT335D
Triple-redundant dynamic tilt sensor and 6-DOF IMU with CAN J1939, developed to ISO 13849 up to PL d.
- Triple-redundant 6-DOF
- ISO 13849 PL d
- CAN J1939 / RS232
- IP69K, 9 to 32 V
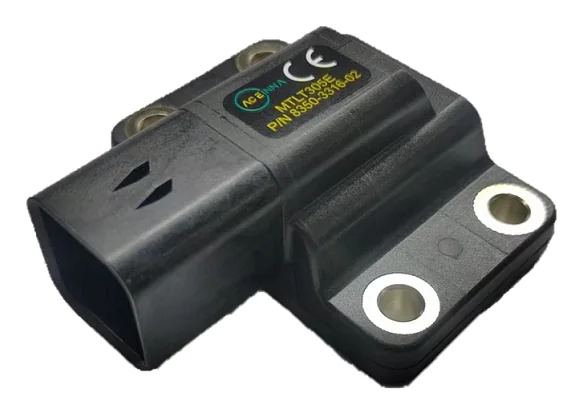
MTLT305E
Cost-effective 6-DOF IMU and dynamic tilt sensor with CAN J1939, software compatible with the MTLT335D.
- 0.15 deg static tilt
- 4 deg/hr gyro bias
- CAN J1939 / RS232
- IP69K, 9 to 32 V
INS401
Automotive GNSS/INS with an RTK receiver and triple-redundant IMU for cm-level positioning.
- RTK 2 cm (RMS)
- Multi-band GNSS
- 100 Hz INS output
- Ethernet, 1PPS
Need help choosing?
Tell us your application. We will recommend the right Aceinna product, quote it and support it after delivery.