Aceinna · Inertial systems
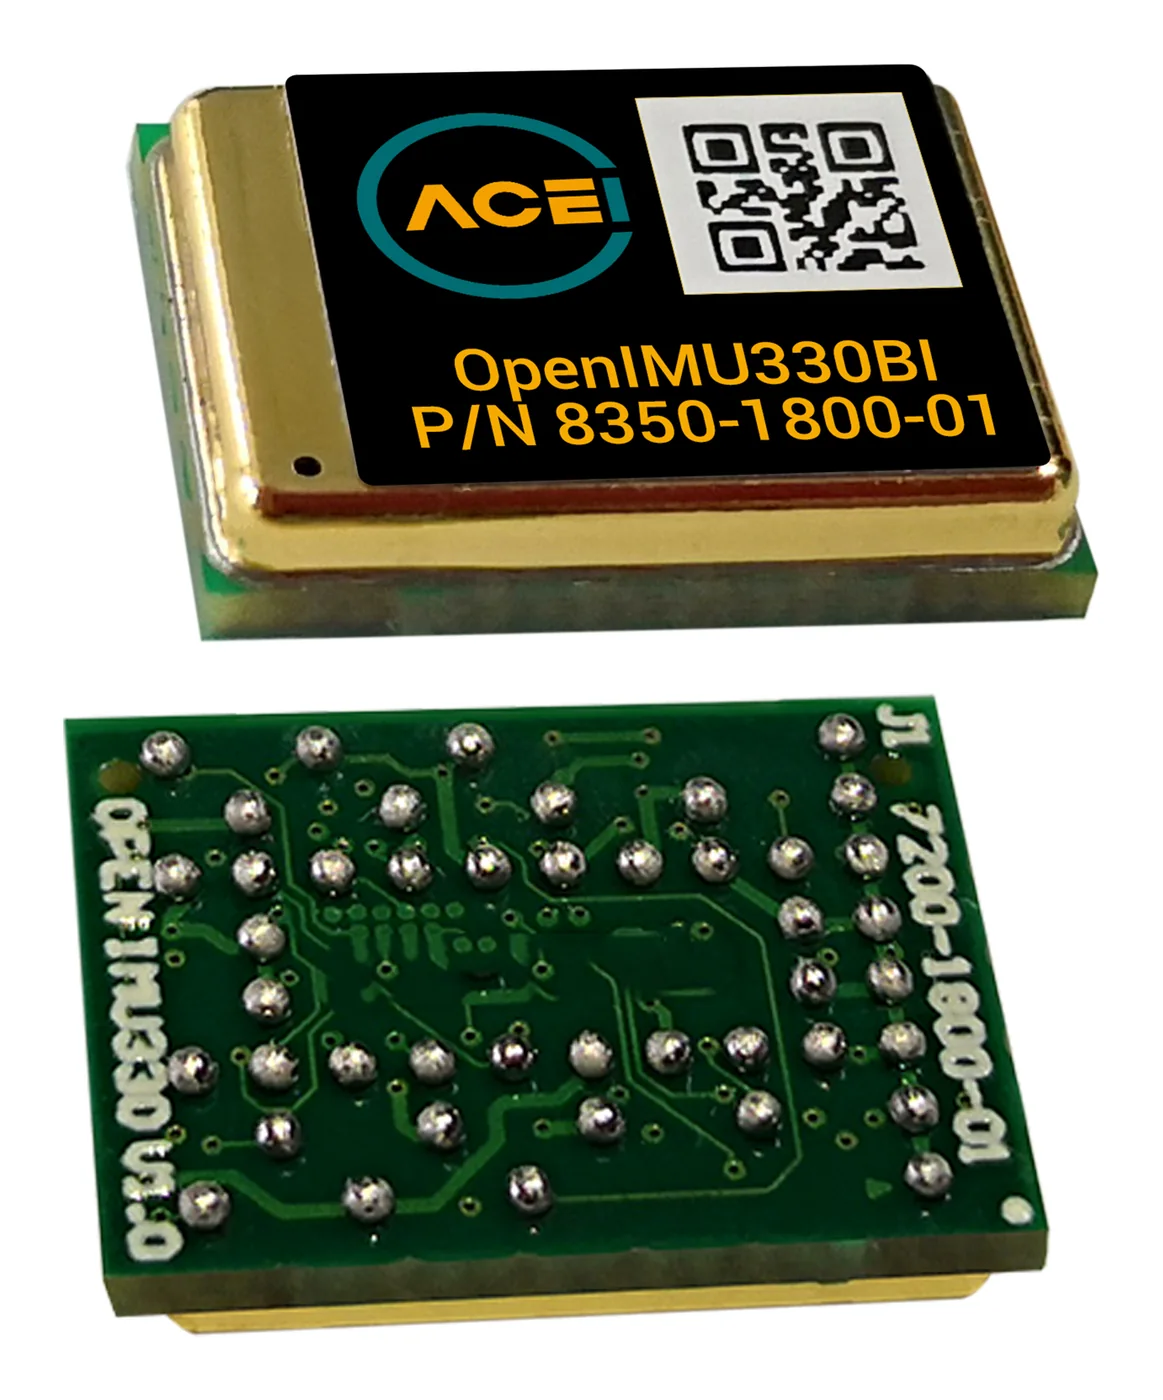
OpenIMU330B
Triple-redundant 6-DOF surface mount IMU that runs the OpenIMU open source navigation stack.
- Triple-redundant 6-DOF
- 1.5 deg/hr gyro bias
- SPI / UART
- 11 x 15 x 3.4 mm BGA
Overview
The OpenIMU330B is a small surface mount 6-DOF inertial measurement unit with triple-redundant 3-axis accelerometers and 3-axis rate gyros. It runs on a 32-bit ARM M4 CPU with floating point unit and uses Aceinna's OpenIMU open source stack, which includes a 16-state extended Kalman filter for attitude and GPS-aided position, velocity and time. Aceinna designed it for automotive Level 3 ADAS and other high-volume applications.
Built for
- Autonomous vehicles
- Self-driving taxis and delivery vehicles
- ADAS systems
- Electronic stability control and lane keep assist
Key features
Triple-redundant sensors
Three sets of 3-axis MEMS gyros and accelerometers support fault-tolerant designs.
Open source algorithms
Runs the OpenIMU stack with a built-in 16-state extended Kalman filter.
ARM M4 processor
A 32-bit ARM M4 CPU with floating point unit runs custom algorithms on the module.
Ready-to-use outputs
IMU, VG-AHRS (roll, pitch, heading) and INS (position, velocity, attitude) algorithms are included.
Free tool chain
VS Code based development tools run on PC, Mac and Ubuntu.
Wide temperature range
Calibrated from -40 to 85 C, with operation specified from -40 to 105 C.
Specifications
- Degrees of freedom
- 6 (3-axis gyro, 3-axis accel)
- Package
- 44-ball BGA, surface mount
- Size
- 11 x 15 x 3.4 mm
- Weight
- 1.0 g
- Gyro range
- +/-400 deg/s
- Gyro bias instability
- 1.5 deg/hr
- Angle random walk
- 0.2 deg/√hr
- Gyro bias over temperature
- 0.3 deg/s
- Accel range
- +/-8 g
- Accel bias instability
- 20 µg
- Bandwidth
- 5 to 50 Hz, configurable
- Interface
- SPI or UART (up to 3 UARTs)
- Output data rate
- 200 Hz SPI, 100 Hz UART
- Input voltage
- 3.0 to 5.5 V, 20 mA typ
- Operating temperature
- -40 to 105 C
- Reliability
- MTBF > 50k hours
Models and options
- OpenIMU330BI (industrial grade)
- OpenIMU330BI EVK (developer kit with EVB, JTAG and test fixture)
Specifications as published by Aceinna. Configurations vary by model; we will confirm the exact build with your quote.
More in inertial systems
All Aceinna products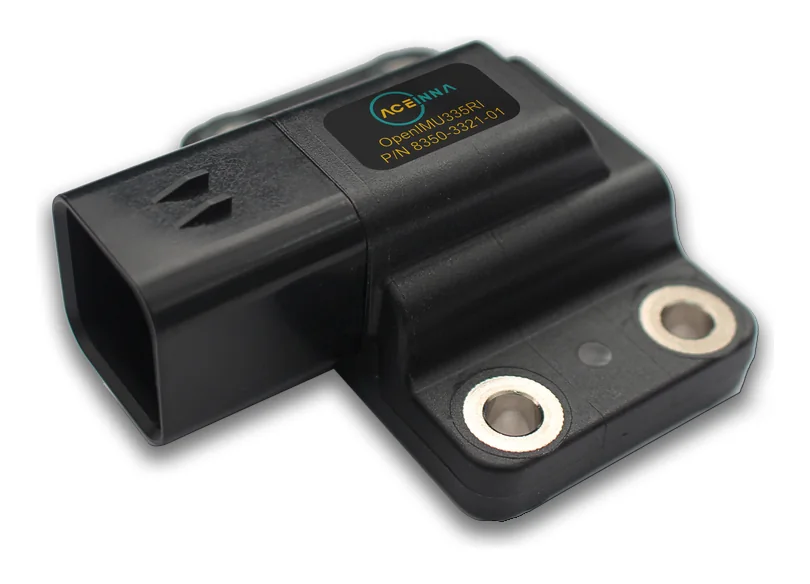
OpenIMU335RI
Rugged, sealed triple-redundant open source IMU with CAN and RS232 for off-road and vehicle use.
- 6-DOF (9-DOF option)
- 1.3 deg/hr gyro bias
- CAN J1939 / RS232
- IP67 / IP69K
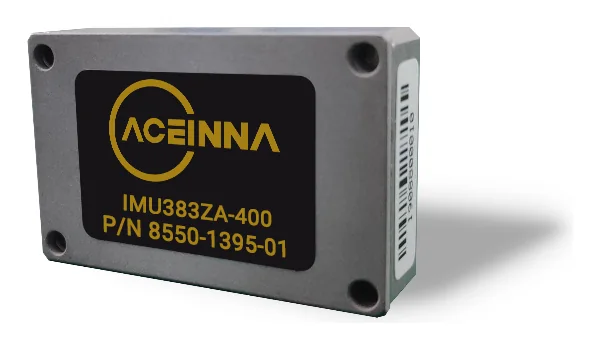
IMU383ZA
Embedded 6-DOF IMU with triple-redundant sensors, a drop-in upgrade for the IMU380ZA and IMU381ZA.
- 6-DOF embedded IMU
- 1.3 deg/hr gyro bias
- SPI or UART
- < 250 mW
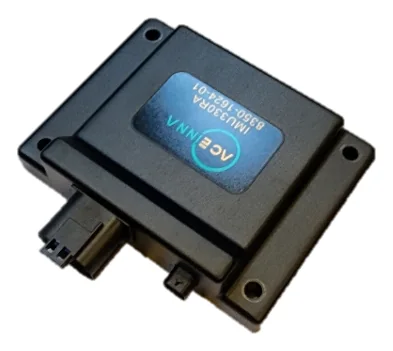
IMU330RA
ASIL B automotive 6-DOF IMU in an IP69K housing with 1000Base-T1 Ethernet and CAN-FD.
- ASIL B, AEC-Q104
- 1000Base-T1 / CAN-FD
- 1 deg/hr gyro bias
- IP69K sealed
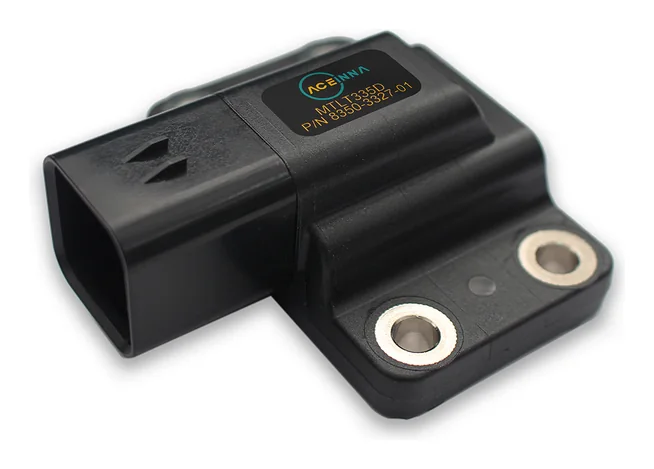
MTLT335D
Triple-redundant dynamic tilt sensor and 6-DOF IMU with CAN J1939, developed to ISO 13849 up to PL d.
- Triple-redundant 6-DOF
- ISO 13849 PL d
- CAN J1939 / RS232
- IP69K, 9 to 32 V
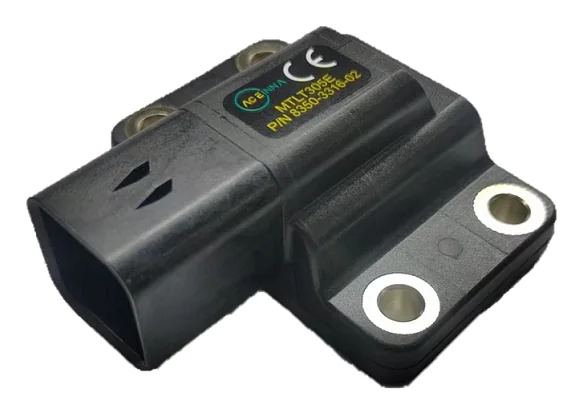
MTLT305E
Lower cost 6-DOF IMU and dynamic tilt sensor with CAN J1939, software compatible with the MTLT335D.
- 0.15 deg static tilt
- 4 deg/hr gyro bias
- CAN J1939 / RS232
- IP69K, 9 to 32 V
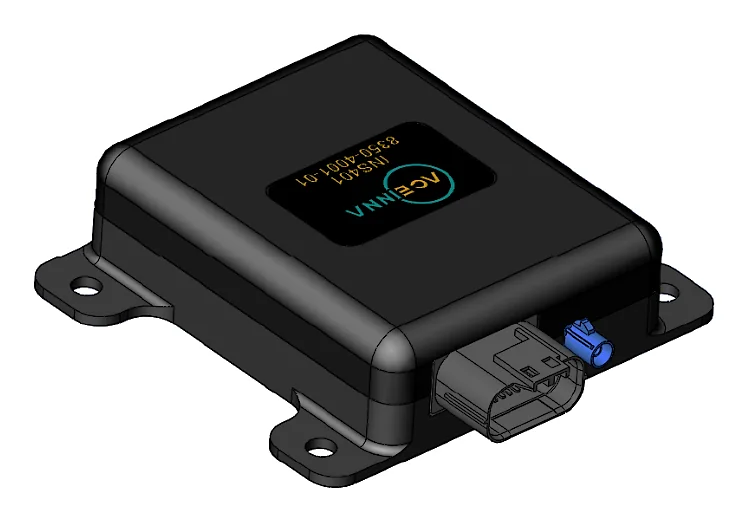
INS401
Automotive GNSS/INS with an RTK receiver and triple-redundant IMU for cm-level positioning.
- RTK 2 cm (RMS)
- Multi-band GNSS
- 100 Hz INS output
- Ethernet, 1PPS
Need help choosing?
Tell us your application. We will recommend the right Aceinna product, quote it and support it after delivery.