Aceinna · Inertial systems
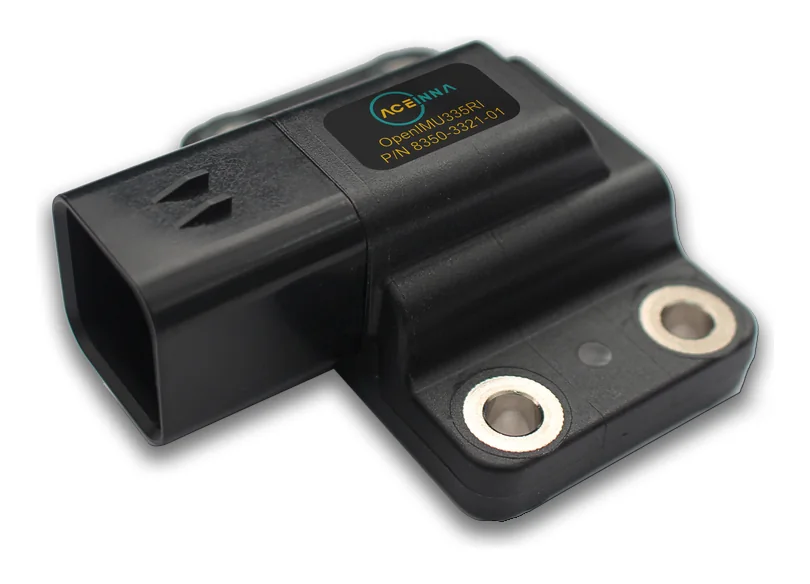
OpenIMU335RI
Rugged, sealed triple-redundant open source IMU with CAN and RS232 for off-road and vehicle use.
- 6-DOF (9-DOF option)
- 1.3 deg/hr gyro bias
- CAN J1939 / RS232
- IP67 / IP69K
Overview
The OpenIMU335RI is a 6-DOF open inertial platform in a rugged, sealed over-molded plastic housing, with a 3-axis magnetometer available as an option. It contains triple-redundant 3-axis MEMS accelerometers and rate gyros calibrated over the operating temperature range, a 168 MHz ARM M4 CPU, and runs the OpenIMU open source stack with a 16-state Kalman filter. It is designed for 12 V and 24 V vehicle platforms in the automotive, construction and agriculture markets.
Built for
- Construction vehicle boom, bucket and cab attitude
- Agriculture vehicles and implements
- Forklifts and robotics control
- Antenna and camera stabilization
Key features
Triple-redundant sensing
Redundant accelerometers and gyros with fault detection.
Open source algorithms
OpenIMU stack with VG, AHRS and INS algorithms and a 16-state EKF.
Wheel speed aiding
Can use wheel speed CAN messages on the bus to improve accuracy.
Flexible mounting
Axes can be reassigned and a user rotation matrix corrects mounting errors.
Vehicle power ready
Runs from 9 to 32 V and is tested to SAE J1455 and ISO 16750-2 electrical loads.
Sealed connector
IP67 Ampseal 16, 6-position connector.
Specifications
- Degrees of freedom
- 6 (9 with optional magnetometer)
- Gyro range
- +/-400 deg/s
- Gyro bias instability
- 1.3 deg/hr
- Angle random walk
- 0.15 deg/√hr
- Gyro bias over temperature
- 0.1 deg/s
- Accel range
- +/-8 g
- Accel bias instability
- 20 µg
- Pitch / roll accuracy
- 0.1 deg over temperature and angle
- Magnetometer range (option)
- +/-8 Gauss
- Interfaces
- CAN 2.0 J1939, RS232
- Max output data rate
- 100 / 200 Hz (CAN / serial)
- Input voltage
- 9 to 32 V
- Power
- 500 mW typ (40 mA at 12 V)
- Operating temperature
- -40 to 85 C
- Size
- 65 x 66 x 27 mm
- Weight
- < 75 g
Models and options
- OpenIMU335RI (industrial grade, 6 DOF)
- OpenIMU335RI EVK (developer kit with JTAG, ST-Link and cable)
Specifications as published by Aceinna. Configurations vary by model; we will confirm the exact build with your quote.
More in inertial systems
All Aceinna products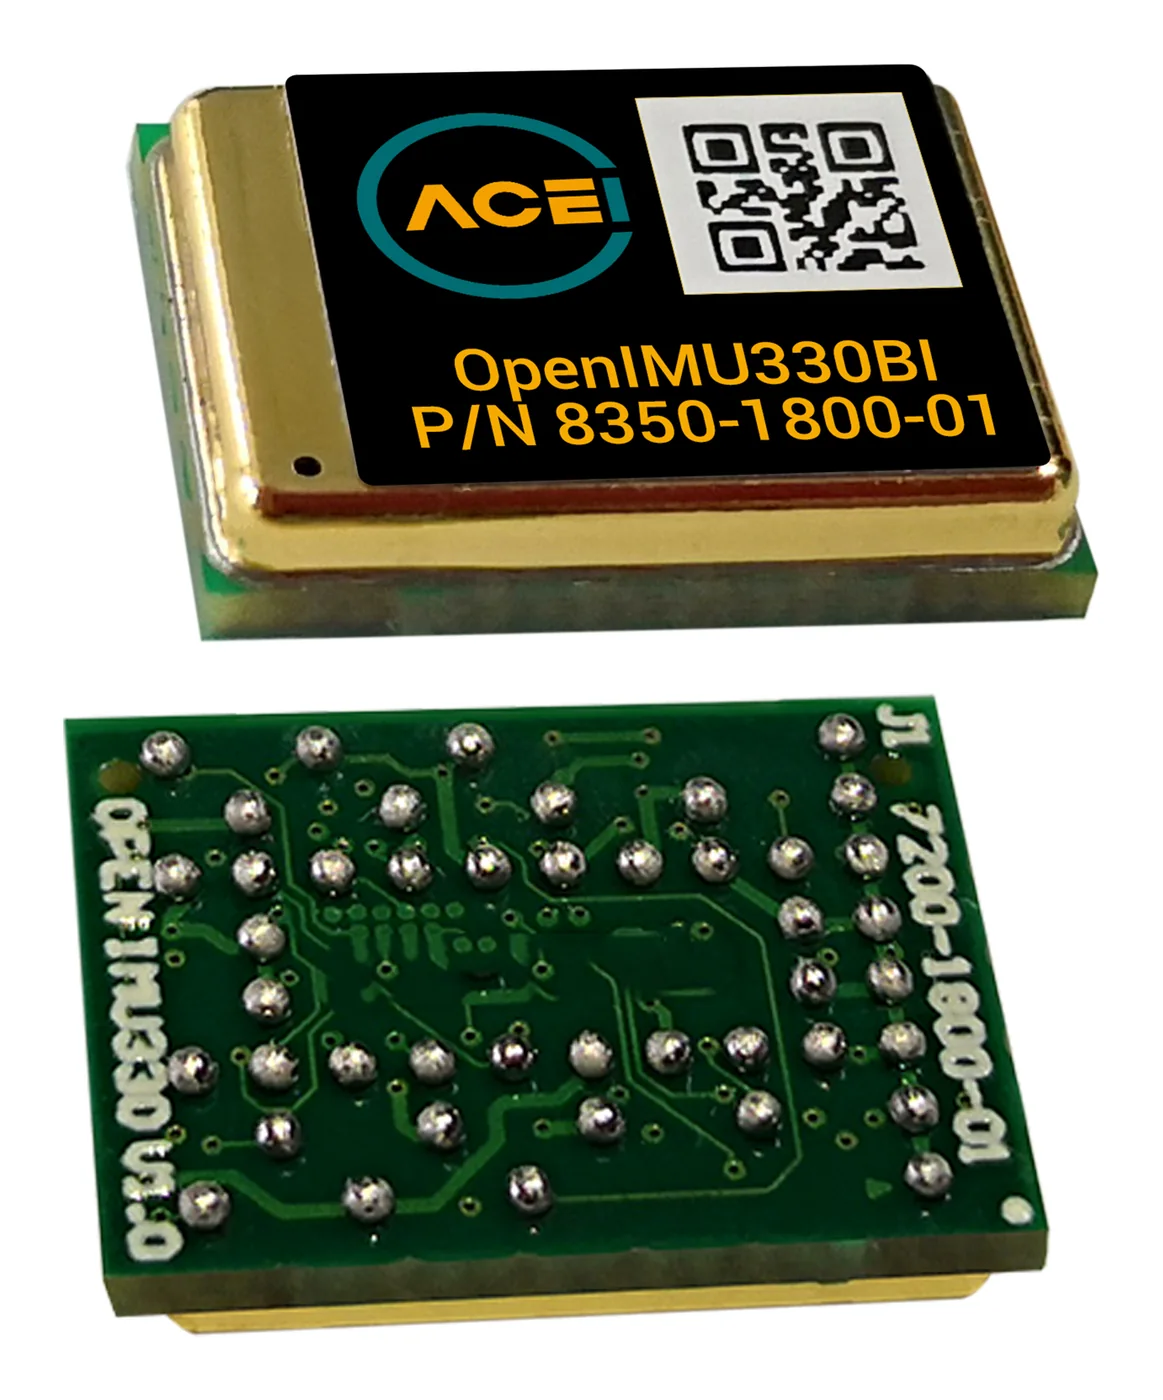
OpenIMU330B
Triple-redundant 6-DOF surface mount IMU that runs the OpenIMU open source navigation stack.
- Triple-redundant 6-DOF
- 1.5 deg/hr gyro bias
- SPI / UART
- 11 x 15 x 3.4 mm BGA
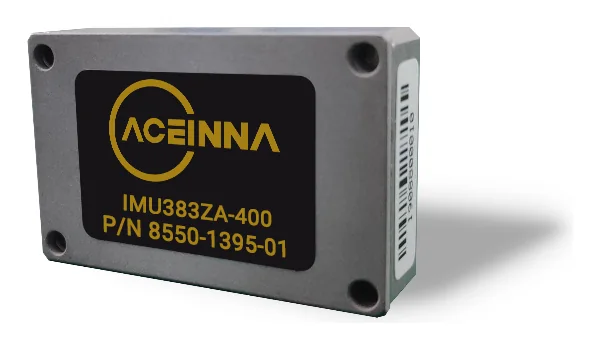
IMU383ZA
Embedded 6-DOF IMU with triple-redundant sensors, a drop-in upgrade for the IMU380ZA and IMU381ZA.
- 6-DOF embedded IMU
- 1.3 deg/hr gyro bias
- SPI or UART
- < 250 mW
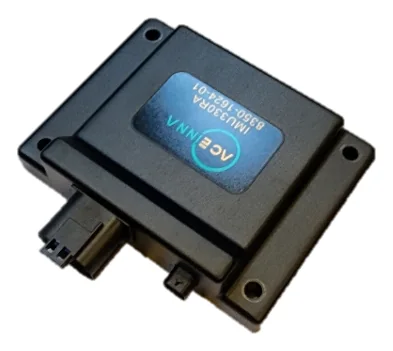
IMU330RA
ASIL B automotive 6-DOF IMU in an IP69K housing with 1000Base-T1 Ethernet and CAN-FD.
- ASIL B, AEC-Q104
- 1000Base-T1 / CAN-FD
- 1 deg/hr gyro bias
- IP69K sealed
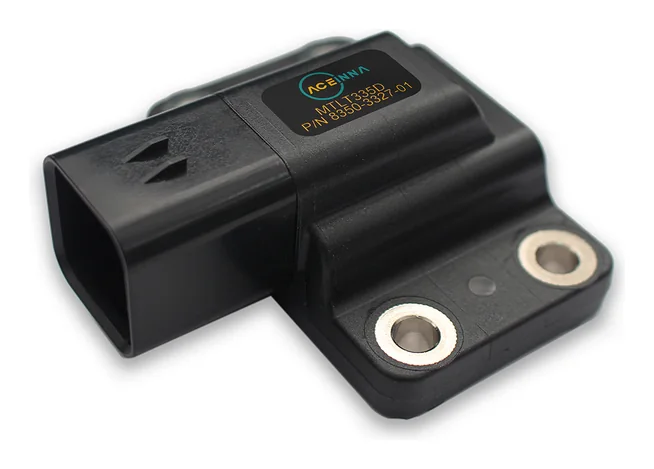
MTLT335D
Triple-redundant dynamic tilt sensor and 6-DOF IMU with CAN J1939, developed to ISO 13849 up to PL d.
- Triple-redundant 6-DOF
- ISO 13849 PL d
- CAN J1939 / RS232
- IP69K, 9 to 32 V
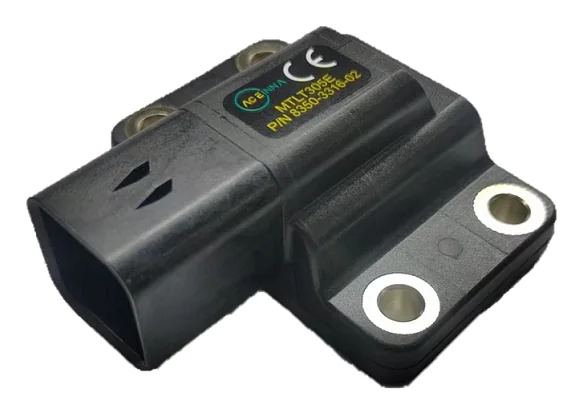
MTLT305E
Lower cost 6-DOF IMU and dynamic tilt sensor with CAN J1939, software compatible with the MTLT335D.
- 0.15 deg static tilt
- 4 deg/hr gyro bias
- CAN J1939 / RS232
- IP69K, 9 to 32 V
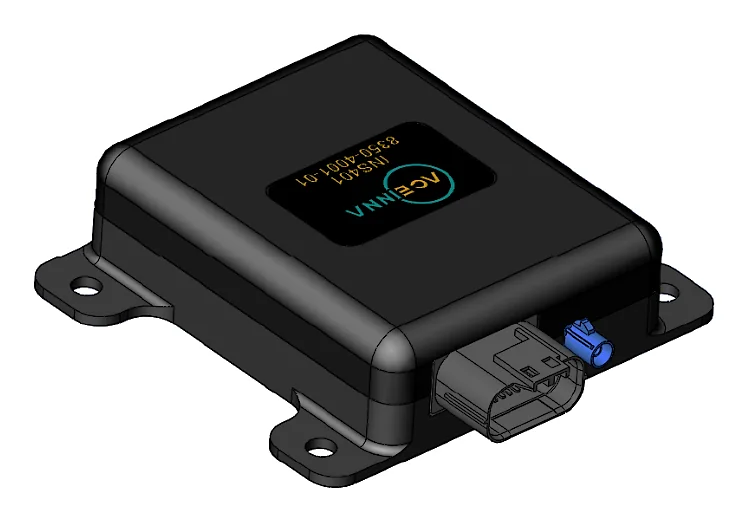
INS401
Automotive GNSS/INS with an RTK receiver and triple-redundant IMU for cm-level positioning.
- RTK 2 cm (RMS)
- Multi-band GNSS
- 100 Hz INS output
- Ethernet, 1PPS
Need help choosing?
Tell us your application. We will recommend the right Aceinna product, quote it and support it after delivery.